What is already running in China
In August 2026, I travelled to Beijing, Guangzhou and Shenzhen with around twenty other European mobility professionals for a study tour on autonomous vehicles (organised by Espaces-Mobilités, with the support of EIT Urban Mobility and CCI France Chine). The programme included twelve meetings with vehicle manufacturers, technology suppliers, autonomous vehicle operators, public transport operators and authorities, combined with test rides in vehicles operated by Baidu Apollo, WeRide, Pony.ai, DiDi and Neolix.
What we saw in those three cities was not just a demonstration. Level 4 robotaxis are carrying passengers in Chinese cities today, while autonomous delivery vehicles are already part of urban logistics. On the other side of the Pacific, Waymo is operating autonomous ride-hailing services at city scale as well.
“I was quite excited to test the robottaxis for the first time. But actually, after 5 minutes it felt so smooth and familiar that I almost forgot the car was driving fully autonomously.”
The engineering is impressive, but it was not what stayed with me. Two other questions came up in almost every meeting: where is the vehicle allowed to drive, and where is it allowed to stop? They are set as technical parameters and are important decisions about public space.
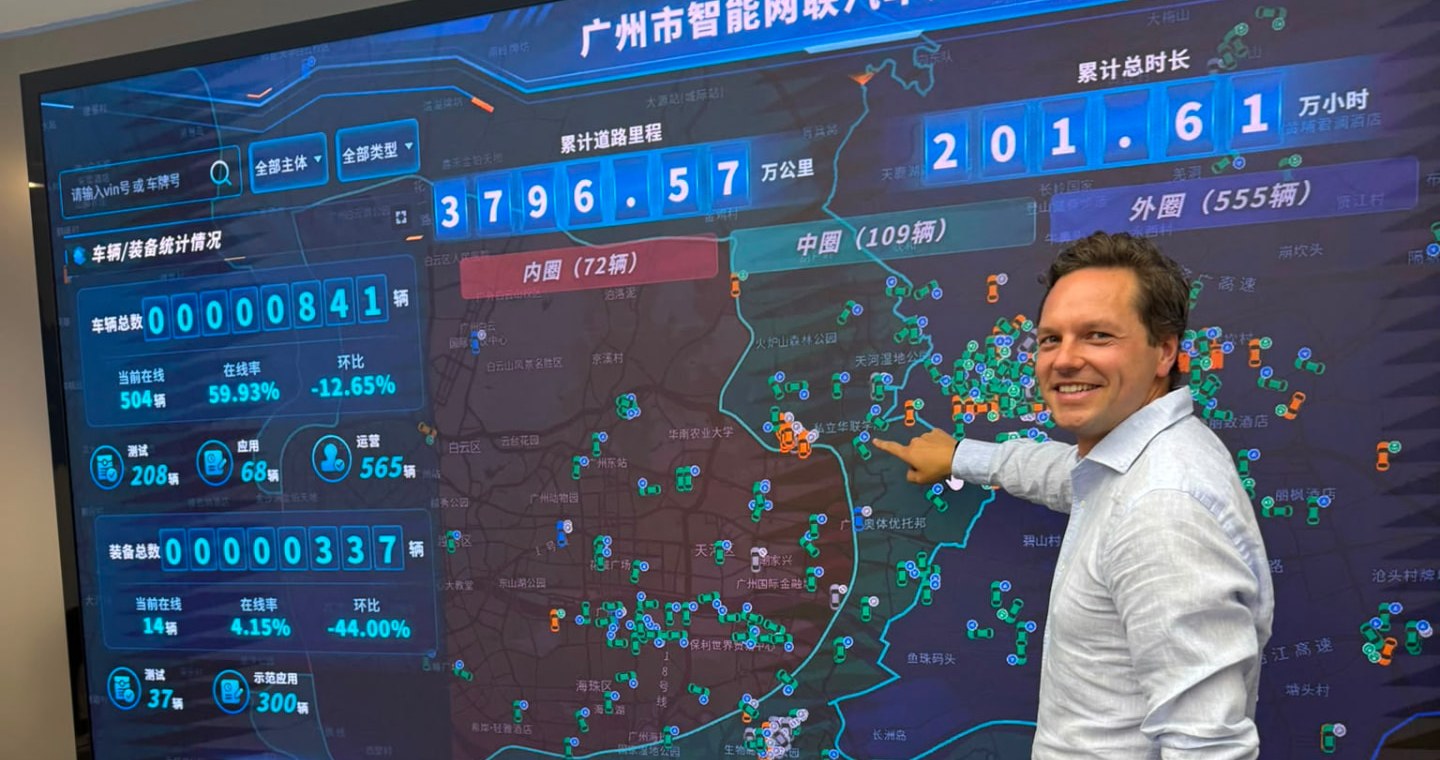
Guangzhou offers an interesting example. They run a safety monitoring platform for intelligent connected vehicles, which brings vehicles from multiple registered companies and consortia onto a single live map of the network. When we visited in August 2026, the platform showed 841 registered vehicles, 37.97 million cumulative monitored kilometres and 2.02 million cumulative hours of operation.
But that platform is not just a local initiative. Guangzhou is one of twenty cities in China's national vehicle-road-cloud integration pilot, led by the Ministry of Industry and Information Technology together with four other ministries. The programme is developing cloud-control infrastructure and a more unified approach to testing and evaluation.
The regulatory framework is developing alongside it. In February 2025, Guangzhou introduced an ordinance for intelligent connected vehicles covering road testing, demonstration operations and phased deployment.
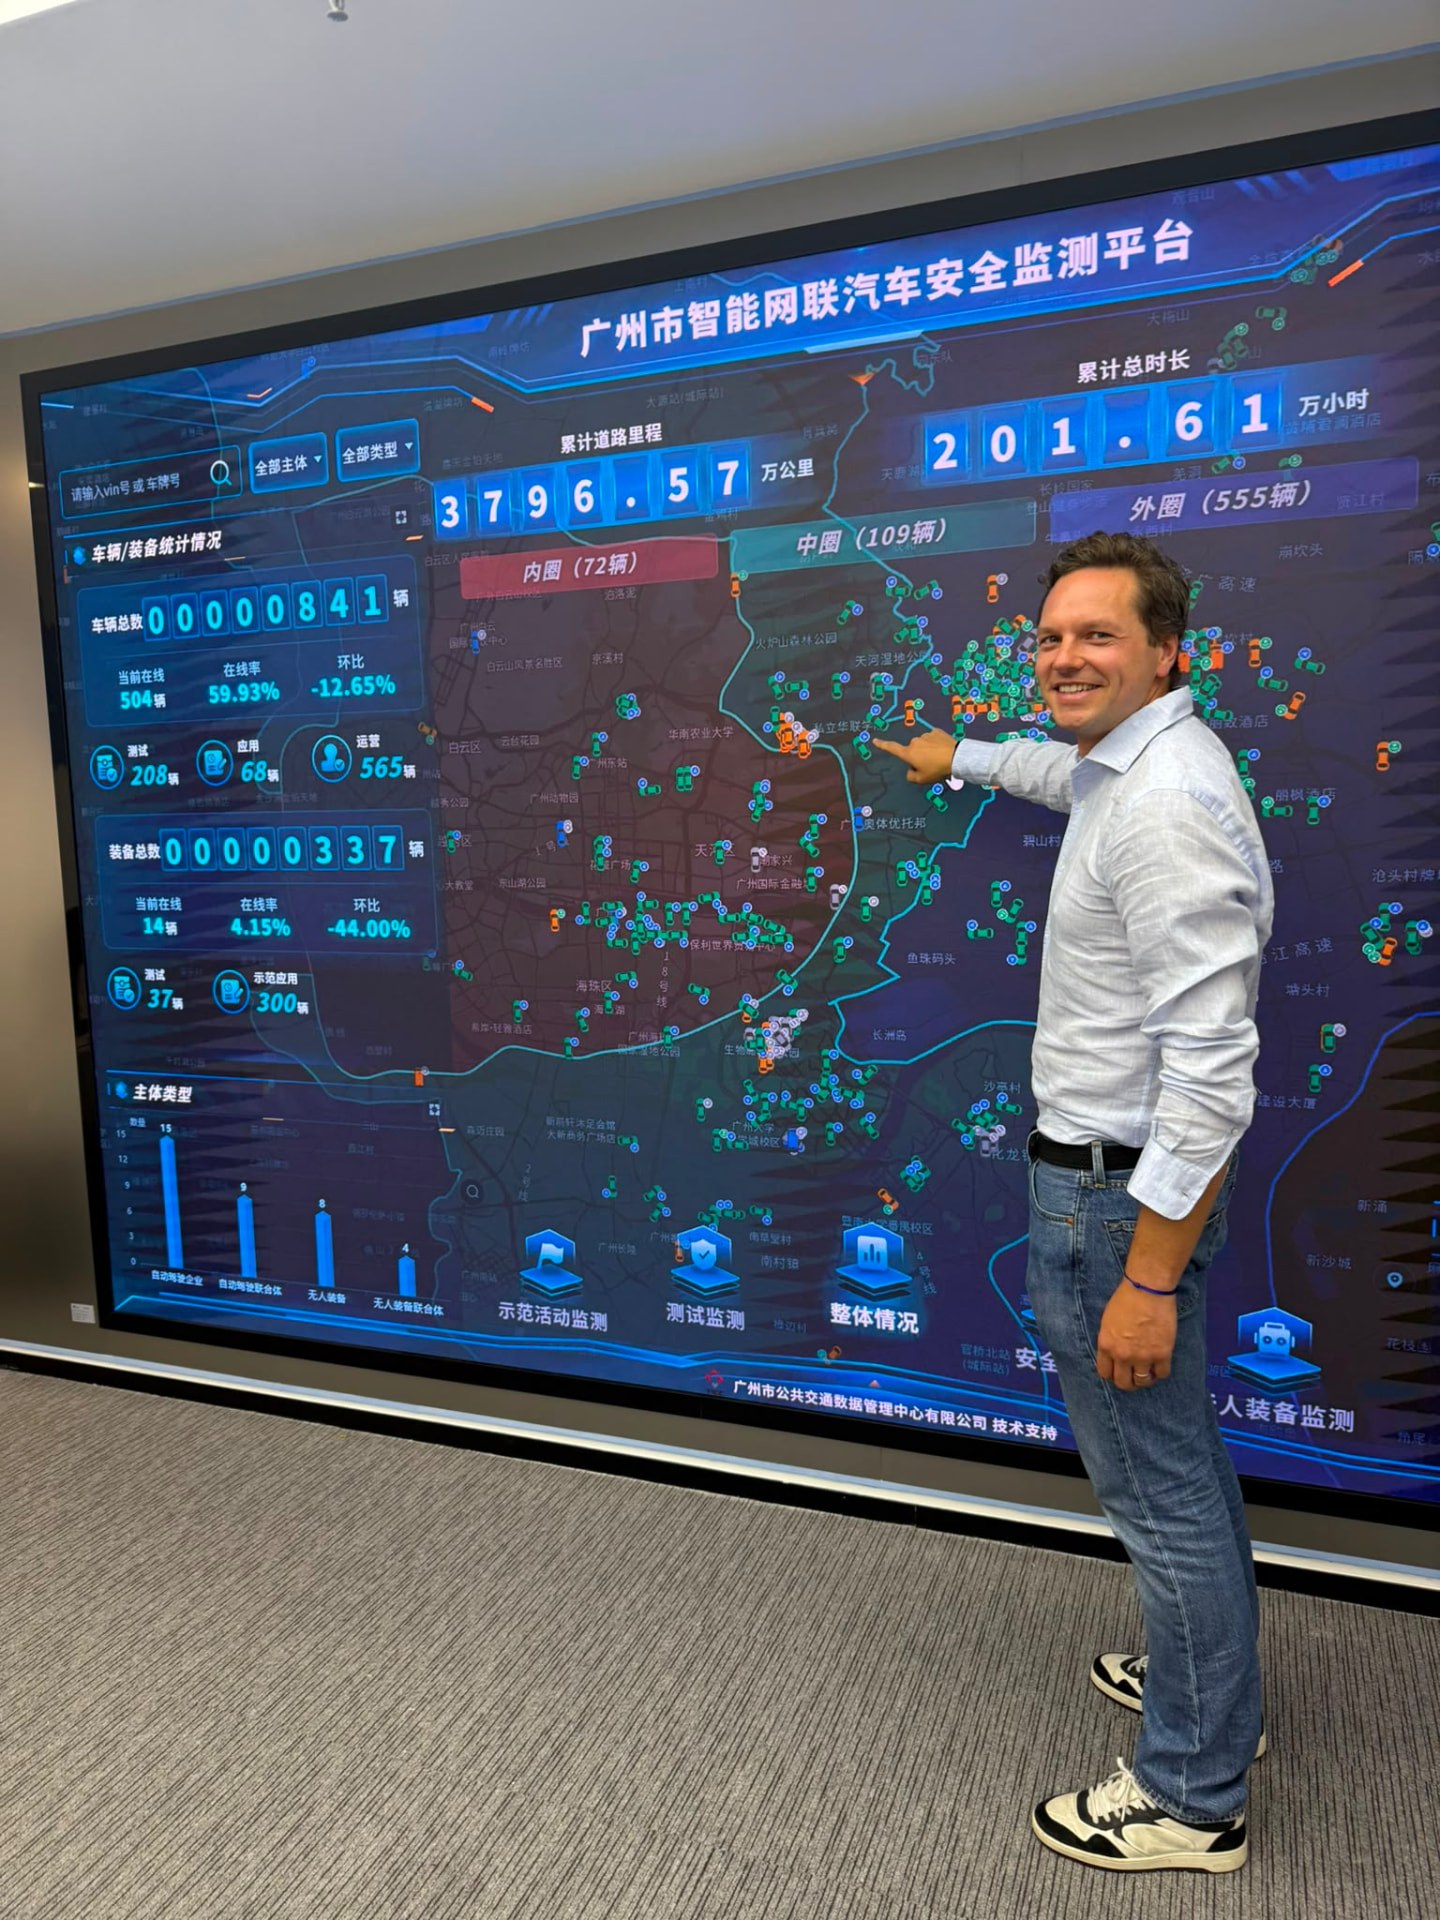
For me, the interesting part is the overview this gives the authority. A single view of what is happening across every operator on the network, rather than having separate reports of each.
And when you look at the map, another thing becomes very visible: autonomous vehicles do not simply operate everywhere. In Guangzhou it is divided into three concentric zones, with a different number of vehicles counted in each. Their operating areas are clearly defined: their Operating Design Domain.
What is an Operating Design Domain?
An Operating Design Domain, or ODD, is the set of conditions under which an autonomous vehicle is permitted to operate. It defines the geographic area, the road types, the times of day, and the weather and traffic conditions within which the vehicle may drive itself. Outside those conditions, the vehicle cannot continue operating autonomously.
In most deployments, an ODD starts relatively small. It can then be expanded as the operator gains experience and demonstrates that the vehicle can safely handle more complex situations.
Technically, you can think of an ODD as a geofence combined with a set of rules. it is a right to operate on a specific part of the network under specific conditions, and it is a right that can be narrowed or withdrawn.
Examples from current European and Chinese deployments show how much policy sits inside it:
- an ODD that excludes school zones during peak hours
- an ODD for an autonomous bus that excludes railway level crossings, as is the case in Leuven
- an ODD that is suspended during events and in heavy weather
Each of those is a judgement about acceptable risk in a specific public space.
Why autonomous vehicles need pick-up and drop-off locations
Autonomous vehicles cannot just pull over wherever a passenger happens to request a ride. Otherwise they would stop in front of a gate, in the middle of a roundabout, in an emergency access lane or hospital entrance, ... From a vehicle's perspective those could all simply be places where a passenger asked to be picked up.
For obvious practical reasons, autonomous vehicles use predefined Pick-up and Drop-off locations, or PUDOs, with a maximum waiting time per location, typically three to five minutes.
A PUDO is therefore a curbside allocation. It grants a vehicle the right to occupy a stretch of public space for a limited time, at the expense of whatever else that curb could serve. Cities already manage exactly these kind of rights for delivery zones, loading bays, taxi ranks, disabled parking and shared vehicles. A PUDO adds autonomous vehicles to that same curbside space.
The difference is scale. An autonomous fleet may request access to those locations thousands of times a day. The rules therefore need to be available digitally and in a format that vehicles and operators can use automatically.
Autonomous vehicles in Europe: Level 2 on the road, Level 4 in pilots
Europe is not starting from zero. Level 2 driver assistance is permitted for all drivers in Belgium and is already in use everyday. At Level 2, the vehicle may assist with steering, acceleration and braking, but the driver remains responsible at all times.
Level 4 is very different. Within its approved Operating Design Domain, the vehicle performs the driving task itself. Instead of a driver supervising the vehicle from the front seat, operations can also be monitored remotely. Level 4 is at pilot stage in a growing number of European cities and regions, including Zurich, Leuven, Croatia, Bratislava, Madrid and Munich.
In each of those pilots an ODD and a set of PUDOs exist. They have to, because no vehicle operates without them. But what varies is who wrote them. Today, those conditions are generally worked out as part of an individual deployment. Depending on the case they are set by the service provider, by the infrastructure operator, or by the two together.
This is manageable with a single operator and a handful of vehicles. But it becomes much more complicated when several autonomous mobility providers start operating on the same road network. Three separately negotiated ODDs and three sets of preferred curb locations produce a city where the rules for autonomous vehicles depend on which app the passenger opened, and a road authority that is no longer setting policy but reconciling contracts. A road authority should not end up with three different sets of rules simply because three different operators entered the market.
What does a road authority need?
Regardless of which operators enter its territory and which technology they use, a road authority needs to be able to:
- Define ODDs and PUDOs itself, as conditions attached to a right to operate, rather than accepting the boundaries proposed by each operator.
- Express those conditions once, in a single machine-readable definition that every operator reads identically, instead of restating them in each bilateral agreement.
- Distribute them digitally to vehicles and operators, and establish that they were received and applied.
- Change them dynamically. Roadworks, an event, an incident or severe weather change what is safe on a given stretch of road within hours. A set of conditions that can only be revised by renegotiating an agreement will always describe a network that no longer exists.
- See what is happening across all operators as one aggregated picture rather than a set of separate operator reports, and verify that operations stayed inside the granted conditions.
Road authorities already decide who has access to certain roads or parts of a city and under which conditions. What changes with autonomous mobility is the speed, scale and the fact that those decisions have to be understood directly by software.
What Europe should settle first
“European, National, Regional and City Road Operators should remain in control of these Autonomous Vehicles by only allowing certified operators that provide their real-time vehicle data, share a portion of their revenu via a connected central hub that also holds the digital dynamic operating design domains as well as pick-up and drop-off points.”
Very little of that list is new for a road authority. Where a vehicle may drive and where it may stop belong to the same family of decisions as a low emission zone, a speed limit, a loading bay or a residential parking permit. They are rights of access to public space: granted under conditions, valid for a defined area and period, and withdrawable when circumstances change. European authorities have been granting and managing rights of that kind for decades.
What is different is who holds the right. A residential parking permit is issued to a person who reads it. An ODD is issued to a fleet of software-driven vehicles that needs the same answer in a form it can act on, updated in near real time, and identical for every operator on the network. So I do not think Europe needs a new category of system here. It needs the category it already has, extended to a new kind of holder.
That also argues for settling the governance model now rather than later. Once several operators are active, managing every deployment through a separate bilateral agreement becomes unworkable. A shared digital framework lets an authority apply the same conditions across its network and still adapt them when the situation changes.
This is also where I see a natural fit for Be-Mobile. Our Mobility Rights Platform already gives authorities a way to define, manage and distribute digital rights to public space across operators. ODDs and PUDOs fit naturally into that same model.
Autonomous vehicles have to fit around cycling and public transport
There is another important European consideration.
Our cities have made a choice that Chinese cities have not: cycling and public transport are the backbone of urban mobility, and everything else fits around them. An autonomous service is not exempt from that. It is one more mode that has to earn its place in a network where the bicycle and the tram come first, and where road space has been deliberately taken away from cars for twenty years.
Take the clearest example: an unbooked autonomous vehicle that keeps driving around the city waiting for its next request, because driving is cheaper than parking. In a city that has spent two decades reducing through traffic, a fleet of empty vehicles circulating by design is not a detail, it is the single most likely way an autonomous service undoes work that took so many years to achieve.
That is exactly the kind of thing an ODD or another operating condition can address, and it is the reason those conditions should not be left to the technology provider.
Road authorities still decide how their network is used. Autonomous mobility adds a new type of operator and a new type of vehicle, but it does not change that responsibility. The moment to set them is before the first commercial service rather than after.
The vehicles will arrive whether or not we are ready. The conditions under which they operate are still open, and they are still ours to set. Before autonomous services scale in Europe, road authorities need to decide what data operators must provide, where vehicles may drive and stop, and how to apply those conditions consistently across everyone operating on the network.